Ge Zhang张哿
Robot learning, and the data behind it.
I'm a founding member of an early-stage startup in stealth, working on robot learning.
Previously, I was an Applied Scientist at the Robotics and AI Institute (formerly Boston Dynamics AI Institute), where I trained VLA models and diffusion policies on data from UMI-style devices, and built the data pipeline and robot control stack around them. Before that, I shipped the first end-to-end visuomotor picking policy to production at RightHand Robotics.
I build learning-based systems that let robots manipulate the physical world. I focus on (a) visuomotor policy learning and (b) the data collection, curation, and evaluation pipelines behind it.
Ongoing · started at Robotics and AI Institute, 2025
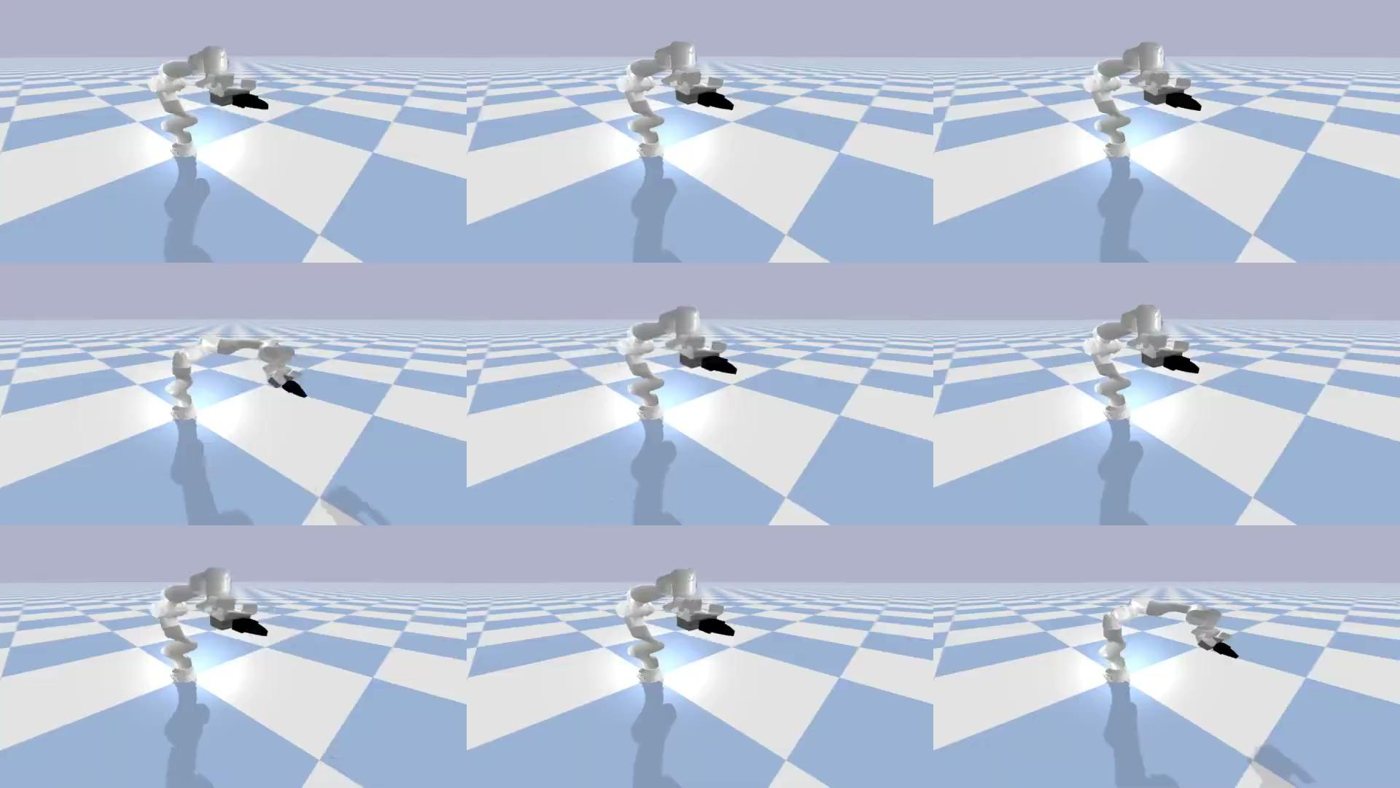
Data Quality Evaluation for Human Demonstrations
A curation pipeline that decides which handheld demonstrations are worth training on, using motion heuristics, chunk-level kinematic replay in simulation, and policy-based consistency scoring. It improved success by 20% on high-accuracy tasks, and the most consistent half of a multi-collector dataset matched the full set.
Robotics and AI Institute, 2025 – 2026
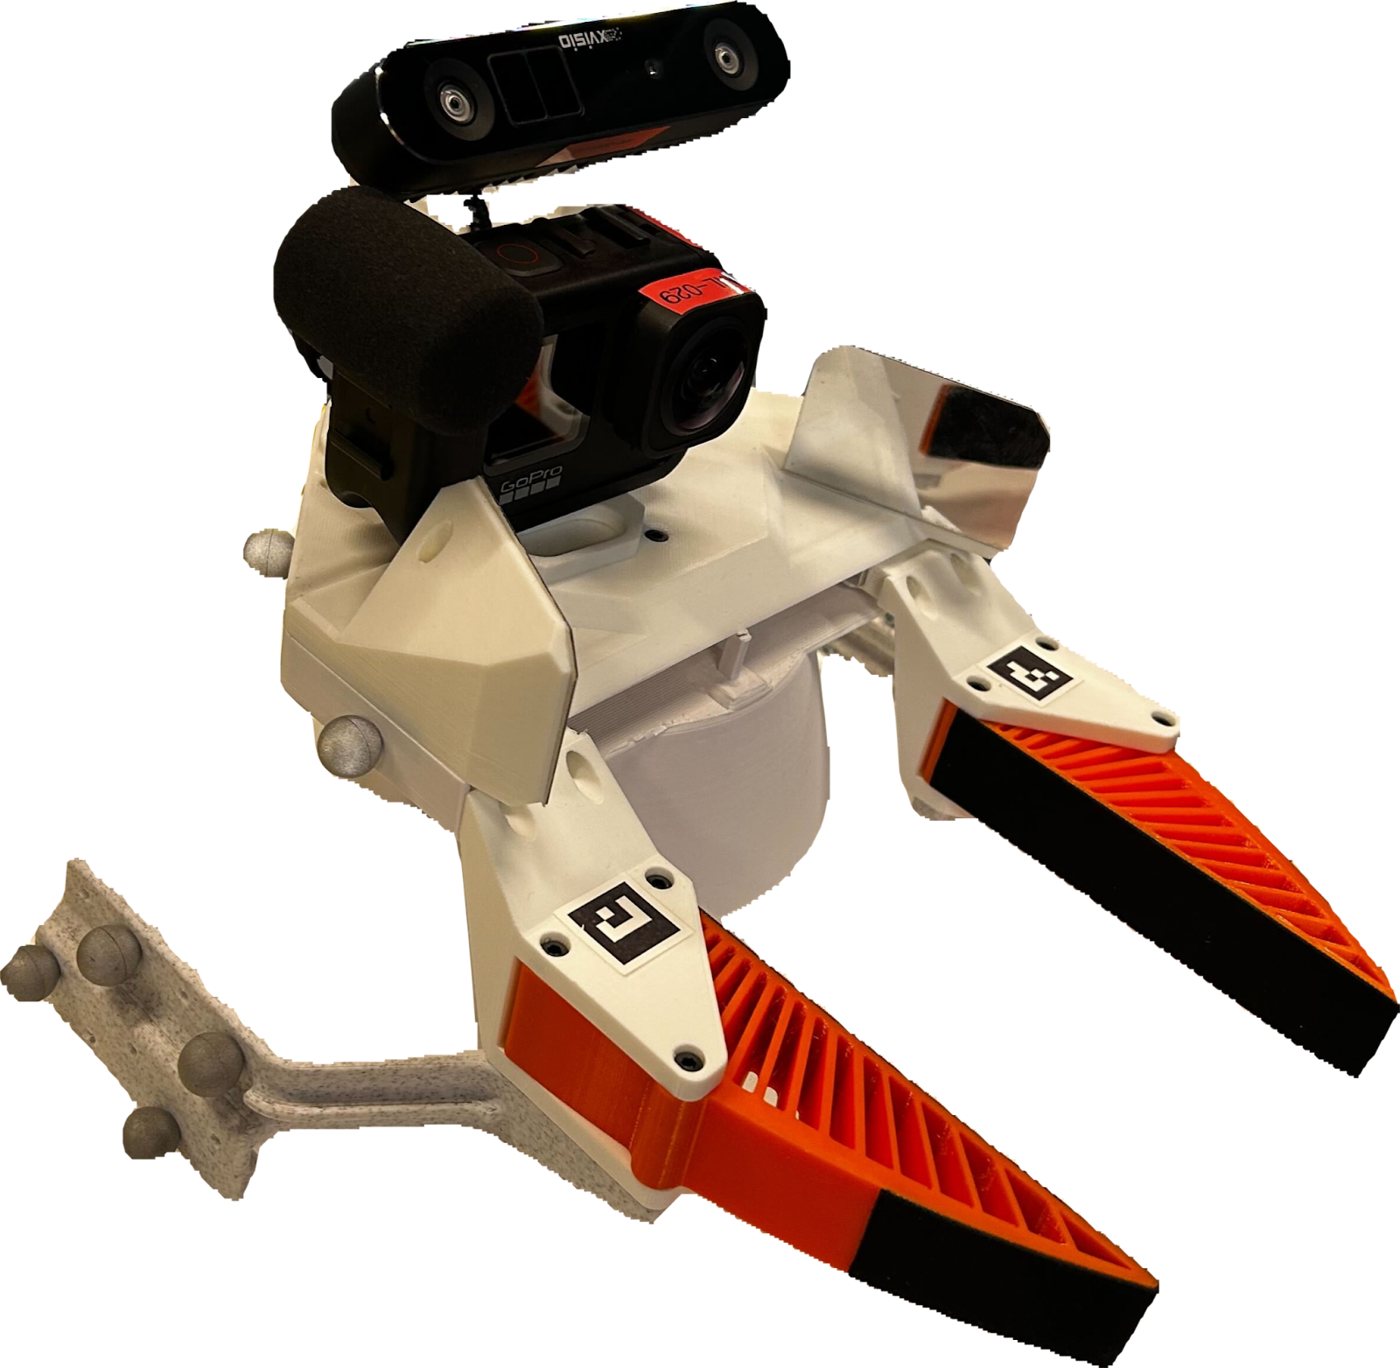
Robot-Free Data Collection: UMI Pipeline and Residual SLAM
Turning 200+ hours of handheld UMI demonstrations into robot policies. I trained a residual model that corrects pose-tracking error (30% lower on seen tasks, 15% on unseen), lifting delicate-task success from 20% to 45%. Also: why fast closed-loop policies can be more precise than their own data.
RightHand Robotics, 2023 – 2024
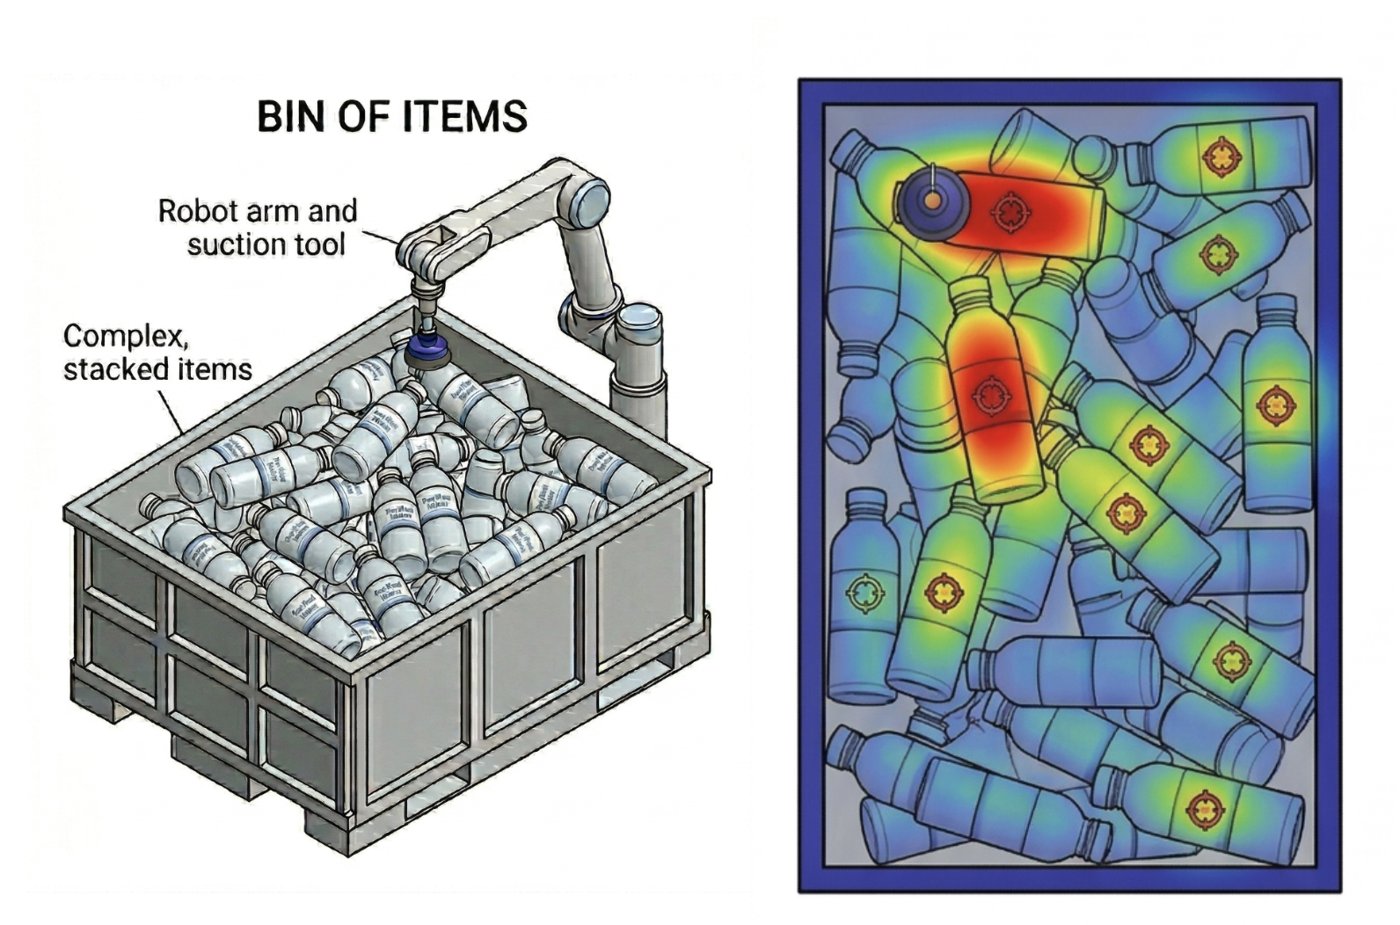
Learned Visuomotor Picking in Production
Replaced a segmentation-based suction heuristic with an end-to-end policy trained on production logs, evaluated with a tier-based benchmark I designed. Deployed with 8% higher pick success on unseen items and 30% fewer trash picks.
ShanghaiTech University, 2019
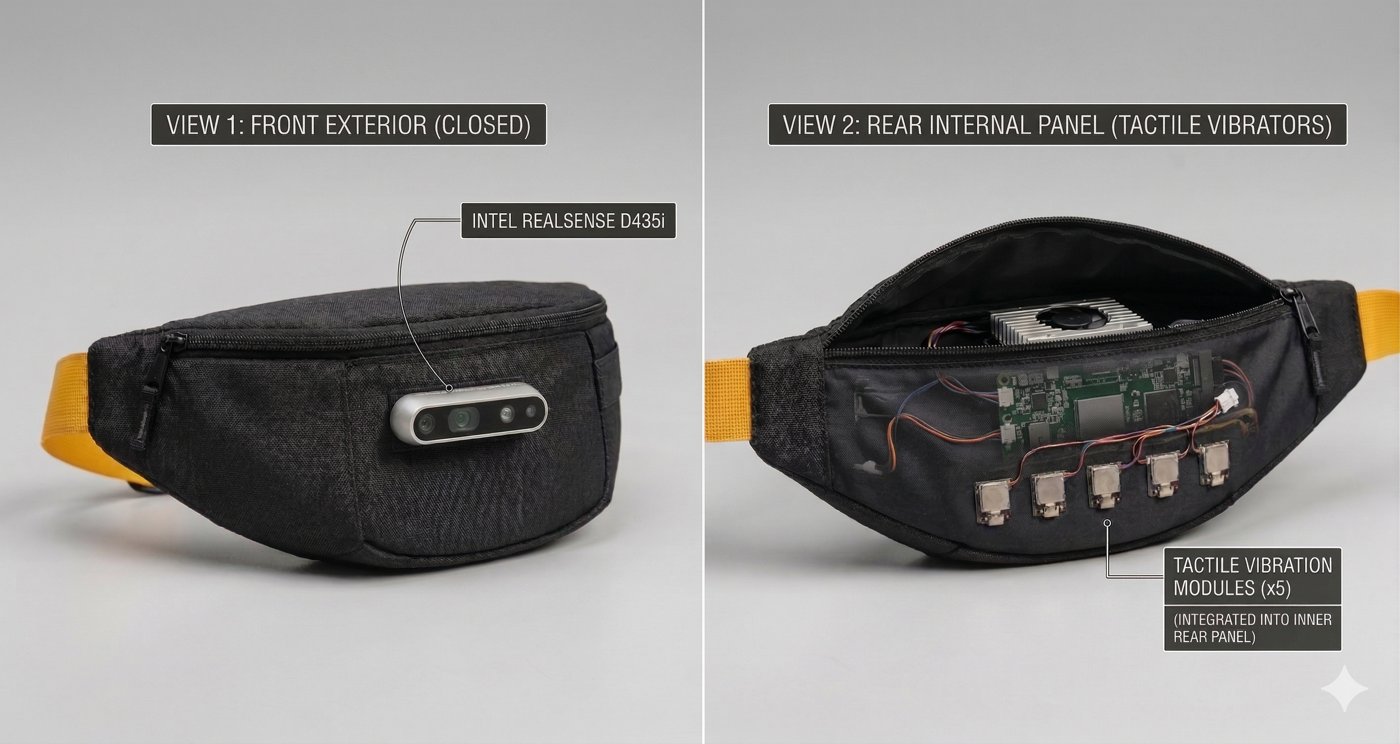
Guidance Waist Pack for the Visually Impaired
A wearable aid that fuses RGB-D, GPS, IMU, and audio on an embedded board for navigation and object detection.
Founding Member
Stealth Startup
Applied Scientist
Software Engineer II, Computer Vision & Machine Learning
Research Collaborator (advisor: Leonidas Guibas)
Stanford University, Geometric Computation Lab
Education
M.S. in Electrical and Computer Engineering
University of Michigan
B.E. in Computer Science
ShanghaiTech University